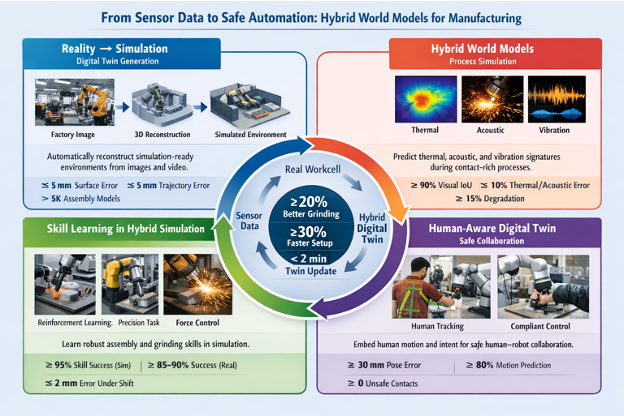
The project addresses the challenge of deploying adaptive, safe automation by engineering hybrid world models that combine deep spatiotemporal predictive learning with robust control theory and safety verification. The framework interprets high-dimensional multi-modal sensor inputs to forecast environmental changes and human motion in real time. Ultimately, this enables industrial robotic systems to dynamically adapt, replan trajectories, and seamlessly cooperate with human workers without risking collisions or operational hazards.
Application/demonstration
The planned demonstration will showcase an industrial robotic manipulator utilizing the hybrid world model to safely and dynamically adapt its trajectory in real time to avoid an active human operator during a high-speed assembly task.